Hello! I'm Vansh Thakur
I am a graduate student in Electrical and Computer Engineering at the University of Michigan, Ann Arbor, working on safe and robust planning and behaviours for autonomous systems.
Currently a Graduate Researcher at ROAHM Lab, I build trajectory optimization solvers for constrained motion planning in high-DoF robotic systems, RL based loco-manipulation stacks, and I have worked on planning and state estimation for autonomous trucks at Mitsubishi Electric.
Publications
LEAP: Gradient Flow Augmented Lagrangian Trajectory Optimization for Contact Constrained Robots
Ramos Chuquiure, C. E., Tsai, R., Zhou, Y., Huang, Z., Thakur, V., Trivedi, A., Lin, Z., Lin, P., Yang, R., Adu, C. E., Vasudevan, R.
arXiv preprint • 2026
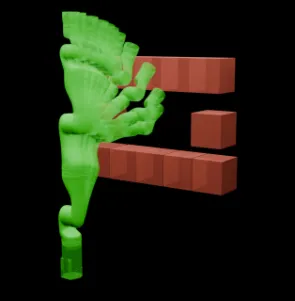
Multiplier-Augmented Geometric Motion Algorithm
Ramos Chuquiure, C. E., Thakur, V., Adu, C. E., Vasudevan, R.
Modeling, Estimation and Control Conference (MECC) • 2026
Research
Rapid Motion Planning, Robust Whole Body Control, and Learned Policies for High DoF Systems
ROAHM Lab, University of Michigan — May 2025–Present
Developed a real-time trajectory optimization system for constrained robotic motion in C++, achieving reliable online planning with strict constraint satisfaction. Deployed on a 7-DoF manipulator with 100% success rate and extended to quadrupeds, leading to an optimization-based whole-body controller for robust contact and stability. Also working on reinforcement learning for high-DoF control, training massively parallelized policies and validating learned behaviors through evaluation rollouts.
Dual-Layer MPC for Autonomous Vehicles in CARLA
University of Michigan — Jan–Apr 2025
Developed a real-time MPC-based planning and control system for autonomous driving, replacing PID control to eliminate instability under urban conditions. Achieved reliable, bounded solve times and validated stable closed-loop behavior in CARLA.
Quadcopter Dynamics, LQR, MRAC & Deep MPC
NIT Hamirpur — Aug 2023–Apr 2024
Developed a robust quadrotor control framework by integrating Model Predictive Control (MPC) with machine learning techniques to handle uncertain dynamics. Analyzed performance trade-offs between traditional and learning-based control approaches, highlighting improvements in adaptability and tracking under uncertainty.
Select Projects
GMR GPU
Fast, GPU-based and differentiable retargeting pipeline for humanoids.
EX-HIQL
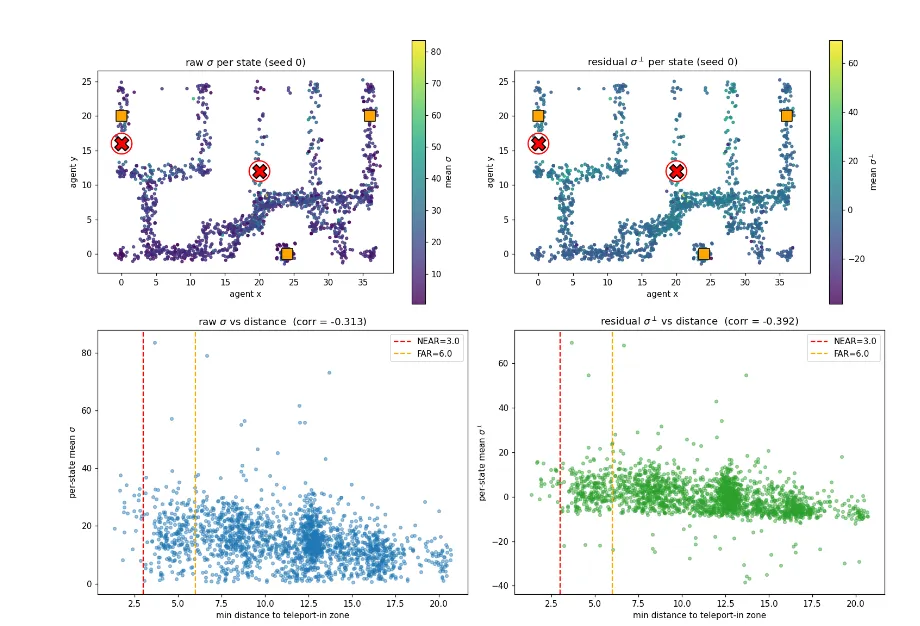
Implemented and analyzed EX-HIQL, identifying the root cause of a 40-point performance collapse in HIQL on stochastic offline GCRL as expectile-regression overestimation at stochastic transitions and a σV–V anti-correlation (r = −0.44). Introduced a per-head τ-vector expectile formulation—a single-tensor modification to the value loss—that preserves ensemble agreement at deterministic transitions while inducing principled disagreement at stochastic ones, yielding a +2.5-point success improvement over HIQL across three seeds and validating the mechanism through residual-σ analysis (1.66× near/far σ ratio, −0.36 distance correlation).
Multivariable Control for Reactive Ion Etching
EECS 565 — Winter 2025
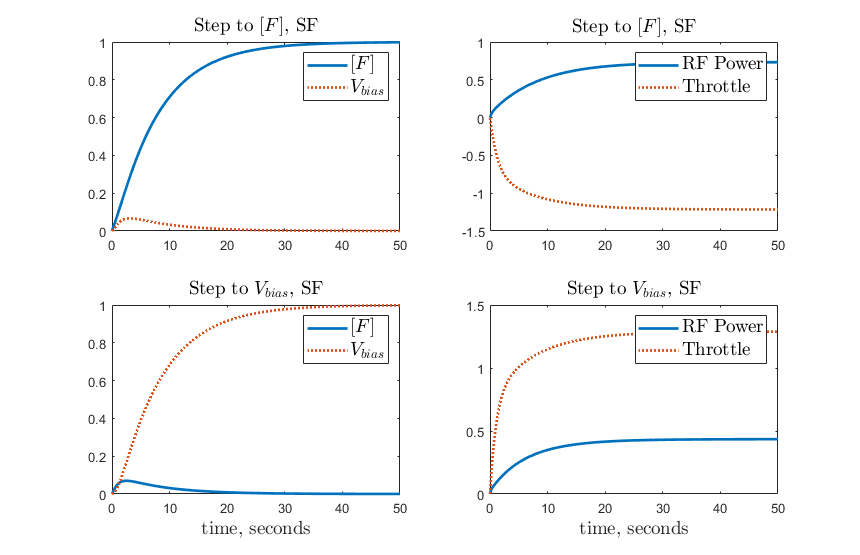
Designed optimal multivariable feedback controller to outperform industry-standard SISO loops for UM's 3x3 RIE plasma chamber. Used LQR + state integrator + Kalman Filter. Reduced voltage spikes by 87% (0.6 → 0.078), halved RF power, and sped up convergence (47s → 11s). Analytically derived SISO limits and outperformed with a reduced 2x3 MIMO design.
Deep Koopman Learning for Chaotic Systems
MECHENG599 Data-Driven Controls — Winter 2025
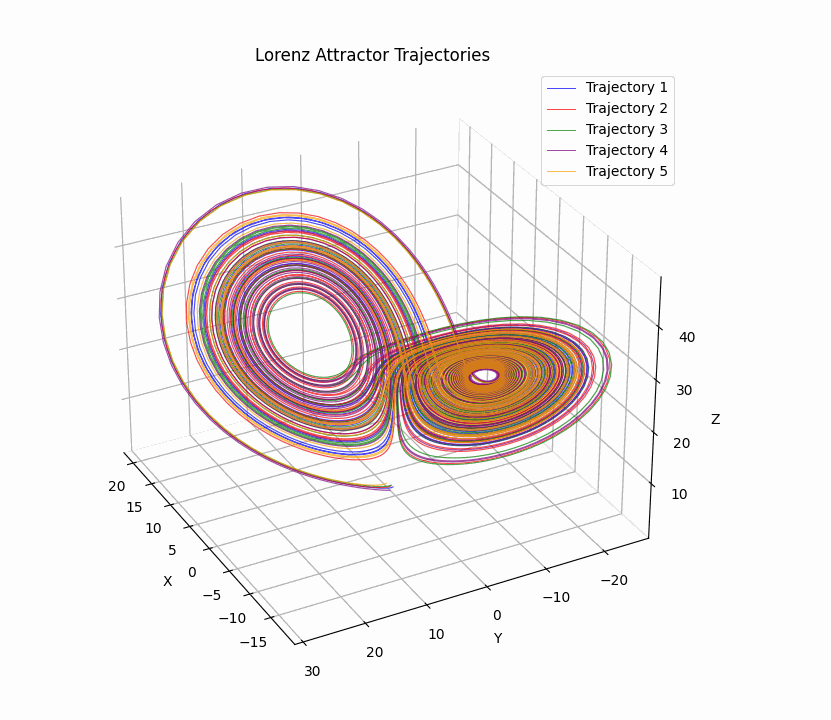
Learned dynamics of the chaotic Lorenz system using neural approximations of the Koopman operator. Trained deep autoencoder in PyTorch to project 3D → 15D latent space; learned linear Koopman dynamics in latent space. Achieved testing MSE ≈ 0.4 across 60k samples of chaotic evolution.
ROB 550: Autonomy Stack for MBot
Fall 2024
Built full autonomy stack for a differential-drive mobile robot using ROS2, SLAM, localization, and motion planning. Implemented occupancy grid mapping from RPLidar data in C++, Monte Carlo Localization with particle filters, and A* path planning for autonomous maze navigation.
EECS 461: Embedded ADAS System on NXP S32K144
Fall 2024
Designed a complete ADAS stack with cruise control and lane keeping using model-based design and embedded C. Built Simulink+C implementation on a physical testbed with haptic steering wheel. Worked with CAN, ISRs, ADCs, and motor encoders.